Autonomous Mobile Robot, Self-Position Estimation Method, Environment Map Generation Method, Environment Map Generating Device, And Environment Map Data Structure
Patent No. EP2256574 (titled "Autonomous Mobile Robot, Self-Position Estimation Method, Environment Map Generation Method, Environment Map Generating Device, And Environment Map Data Structure") was filed by Toyota Jidosha Kabushiki Kaisha on Jan 26, 2009. The application was issued on Jun 17, 2015.
Patent Summary
Patent Family
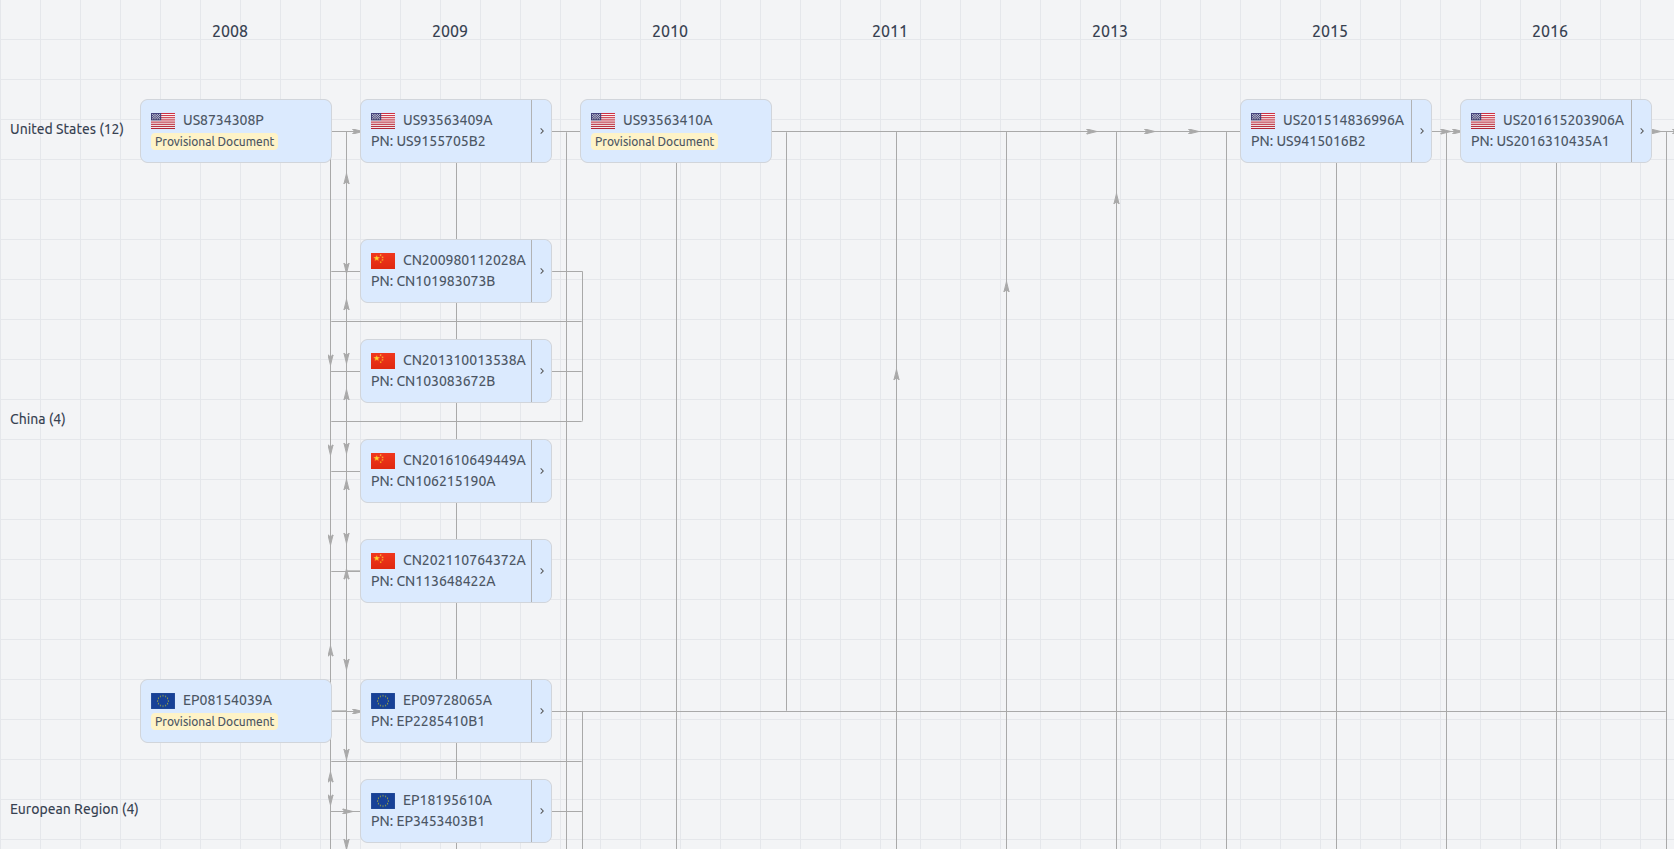
Patent Oppositions
Patent oppositions filed by competitors challenge the validity of a granted patent. These oppositions are typically based on claims of prior art, lack of novelty, or non-obviousness. They are a key part of the process for determining a patent's strength and enforceability.
| Company | Opposition Date | Representative |
|---|---|---|
| VORWERK & INTERHOLDING | Mar 17, 2016 | HORN |
Dossier Documents
The dossier documents provide a comprehensive record of the patent's prosecution history - including filings, correspondence, and decisions made by patent offices - and are crucial for understanding the patent's legal journey and any challenges it may have faced during examination.
Date
Description
Get instant alerts for new documents
Dec 14, 2021
Dec 10, 2021
Dec 10, 2021
Dec 10, 2021
Dec 10, 2021
Dec 10, 2021
Dec 7, 2021
Dec 7, 2021
Dec 6, 2021
Dec 6, 2021
Dec 6, 2021
Nov 5, 2021
Oct 27, 2021
Oct 27, 2021
Oct 27, 2021
Oct 22, 2021
Nov 21, 2018
Nov 19, 2018
Nov 16, 2018
Sep 21, 2018
Aug 2, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jul 27, 2018
Jun 13, 2018
Jun 13, 2018
Jun 7, 2018
Jun 6, 2018
Jun 6, 2018
Jun 6, 2018
May 2, 2018
Apr 13, 2018
Apr 5, 2018
Apr 3, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Mar 27, 2018
Dec 18, 2017
Dec 18, 2017
Dec 18, 2017
Oct 24, 2017
Oct 20, 2017
Oct 20, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 18, 2017
Oct 16, 2017
Oct 16, 2017
Oct 16, 2017
Oct 11, 2017
Oct 10, 2017
Aug 14, 2017
Jul 28, 2017
Jul 19, 2017
Jun 22, 2017
Jun 15, 2017
Jun 15, 2017
Jun 15, 2017
Jun 15, 2017
Jun 15, 2017
Jun 9, 2017
Jun 8, 2017
Jun 8, 2017
May 23, 2017
May 15, 2017
May 15, 2017
May 15, 2017
May 15, 2017
May 10, 2017
May 10, 2017
May 2, 2017
May 2, 2017
May 2, 2017
May 2, 2017
May 2, 2017
May 2, 2017
May 2, 2017
Mar 6, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Feb 23, 2017
Sep 22, 2016
Sep 19, 2016
Sep 19, 2016
Sep 19, 2016
May 9, 2016
May 9, 2016
Apr 8, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 18, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Mar 17, 2016
Jul 9, 2015
Jul 2, 2015
Jun 17, 2015
May 21, 2015
May 1, 2015
May 1, 2015
May 1, 2015
May 1, 2015
May 1, 2015
Jan 7, 2015
Jan 7, 2015
Jan 7, 2015
Jan 7, 2015
Jan 7, 2015
Sep 17, 2013
Sep 17, 2013
Sep 17, 2013
Sep 17, 2013
Sep 17, 2013
Jul 23, 2013
Jul 23, 2013
Mar 18, 2013
Mar 18, 2013
Mar 18, 2013
Mar 18, 2013
Mar 18, 2013
Jan 29, 2013
Jan 18, 2013
Nov 8, 2012
Nov 8, 2012
Mar 15, 2012
Mar 15, 2012
Mar 15, 2012
Nov 24, 2011
Nov 7, 2011
Nov 7, 2011
Nov 7, 2011
Sep 15, 2011
Aug 18, 2011
Jul 29, 2011
Jul 29, 2011
Jul 29, 2011
Jul 29, 2011
Jul 29, 2011
Jul 28, 2011
Jul 28, 2011
Nov 4, 2010
Oct 18, 2010
Oct 6, 2010
Sep 20, 2010
Sep 20, 2010
Sep 20, 2010
Sep 20, 2010
Sep 20, 2010
Sep 20, 2010
Sep 16, 2010
Jul 7, 2010
Sep 23, 2009
Sep 3, 2009
Sep 3, 2009
Sep 3, 2009
EP2256574
- Application Number
- EP09713949A
- Filing Date
- Jan 26, 2009
- Status
- Revoked
- Dec 10, 2021
- Publication Date
- Jun 17, 2015
- External Links
- Slate, Register , Google Patents