An Industrial Robot Having A Kinematically Redundant Arm And A Method For Controlling The Robot
Patent No. EP2699392 (titled "An Industrial Robot Having A Kinematically Redundant Arm And A Method For Controlling The Robot") was filed by ABB Research on Apr 19, 2011. The application was issued on Oct 21, 2015.
Patent Summary
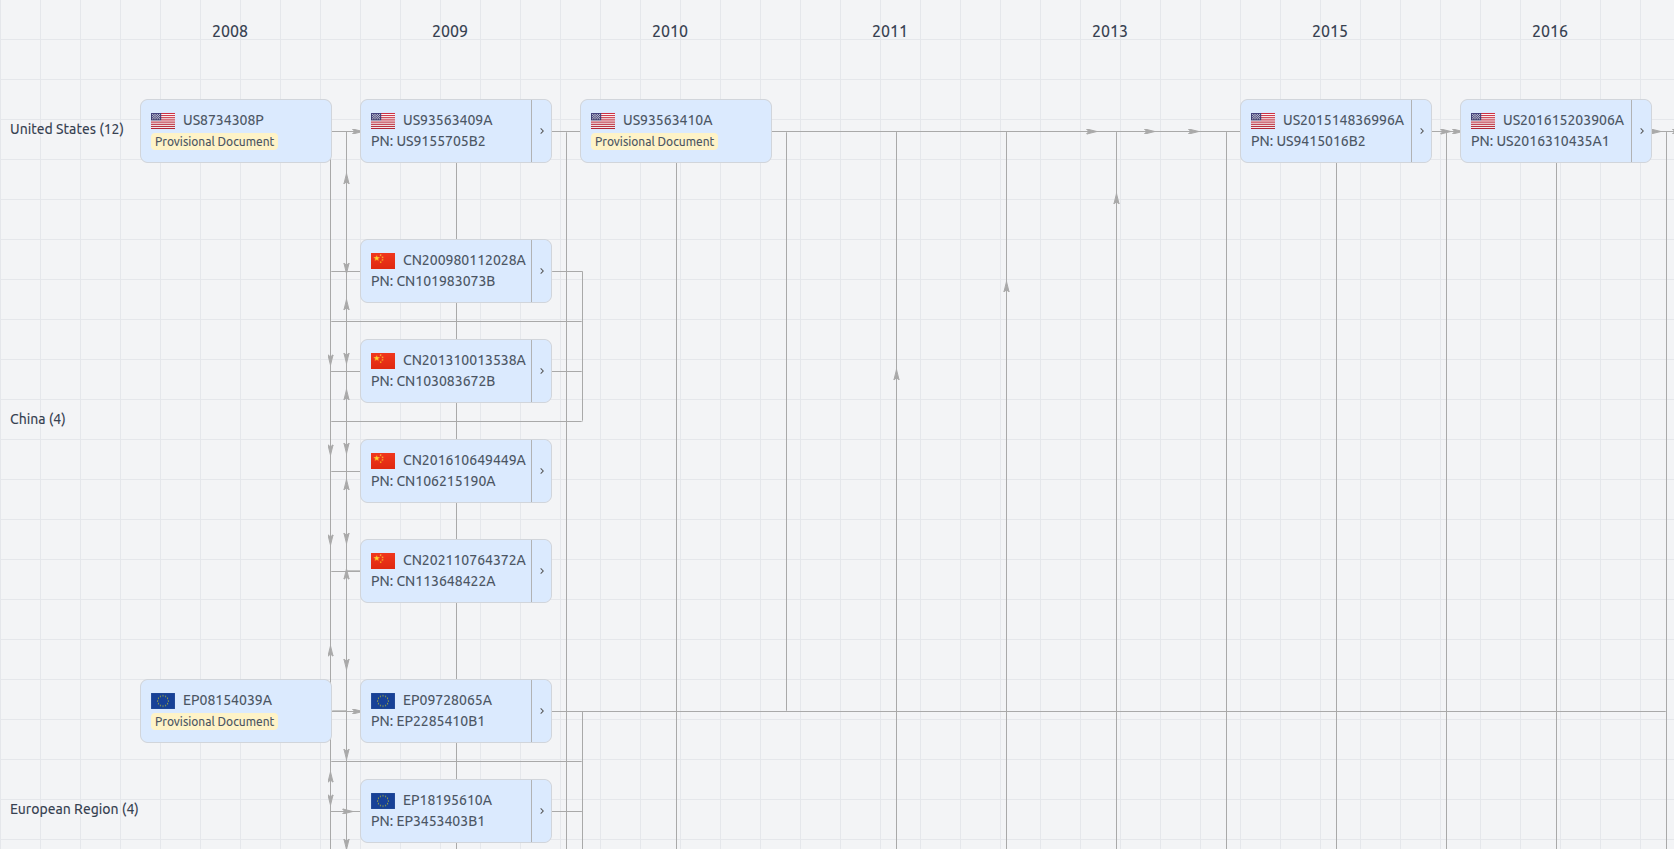
Patent Family
Patent Oppositions
Patent oppositions filed by competitors challenge the validity of a granted patent. These oppositions are typically based on claims of prior art, lack of novelty, or non-obviousness. They are a key part of the process for determining a patent's strength and enforceability.
Dossier Documents
The dossier documents provide a comprehensive record of the patent's prosecution history - including filings, correspondence, and decisions made by patent offices - and are crucial for understanding the patent's legal journey and any challenges it may have faced during examination.
Date
Description
EP2699392
- Application Number
- EP11717215A
- Filing Date
- Apr 19, 2011
- Status
- Revoked
- Oct 13, 2017
- Publication Date
- Oct 21, 2015
- External Links
- Slate, Register , Google Patents